182,69 €
+ 9,99 € Doručenie

Parallel Robots

Predáva:

182,69 €

Na sklade
+ 9,99 € Doručenie

Politika vrátenia 14 dní

Ochrana kupujúceho

Spôsoby platby:

  • Značka: Unbranded

Podrobnosti o produkte

Podrobnosti o produkte

Parallel Robots

Parallel structures are more effective than serial ones for industrial automation applications that require high precision and stiffness or a high load capacity relative to robot weight. Although many industrial applications have adopted parallel structures for their design few textbooks introduce the analysis of such robots in terms of dynamics and control. Filling this gap Parallel Robots: Mechanics and Control presents a systematic approach to analyze the kinematics dynamics and control of parallel robots. It brings together analysis and design tools for engineers and researchers who want to design and implement parallel structures in industry. Covers Kinematics Dynamics and Control in One Volume The book begins with the representation of motion of robots and the kinematic analysis of parallel manipulators. Moving beyond static positioning it then examines a systematic approach to performing Jacobian analysis. A special feature of the book is its detailed coverage of the dynamics and control of parallel manipulators. The text examines dynamic analysis using the Newton-Euler method the principle of virtual work and the Lagrange formulations. Finally the book elaborates on the control of parallel robots considering both motion and force control. It introduces various model-free and model-based controllers and develops robust and adaptive control schemes. It also addresses redundancy resolution schemes in detail. Analysis and Design Tools to Help You Create Parallel Robots In each chapter the author revisits the same case studies to show how the techniques may be applied. The case studies include a planar cable-driven parallel robot part of a promising new generation of parallel structures that will allow for larger workspaces. The MATLABÂ code used for analysis and simulation is available online. Combining the analysis of kinematics and dynamics with methods of designing controllers this text offers a holistic introduction for anyone interested in designing and implementing parallel robots. . Language: English
  • Značka: Unbranded
  • Kategória: Vzdelávanie
  • Formátovať: Paperback
  • Jazyk: English
  • Umelec: Hamid D. Taghirad
  • Dátum vydania: 2017/03/29
  • Vydavateľ / štítok: CRC Press
  • Fruugo ID: 337602402-741240325
  • ISBN: 9781138077386
Sľub

Záruka predávajúceho

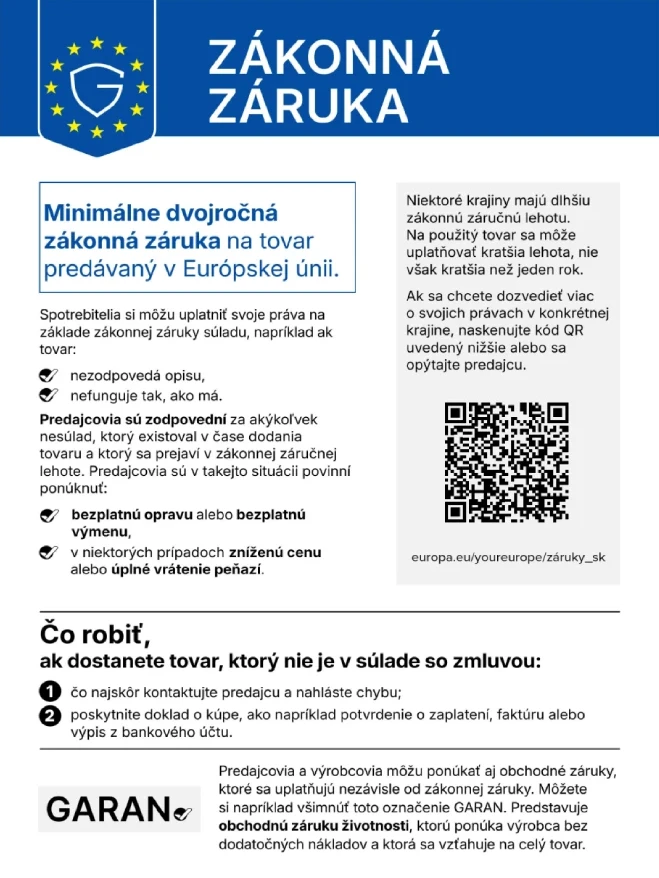
Vrátane 2-ročnej právnej záruky

Vaše spotrebiteľské práva v EÚ zahŕňajú bezplatnú minimálne 2-ročnú právnu záruku

Stiahnuť právnu záruku zhody
Doručenie

Doručenie

Odoslané do 5 dní

  • STANDARD: 13,68 € - Doručenie medzi ut 13 októbra 2026–pi 16 októbra 2026

Doručenie od Spojené kráľovstvo.

Vrátenie tovaru

Vrátenie a zrušenie objednávky

Vrátenie tovaru

Snažíme sa, aby sme výrobky, ktoré si objednáte, doručili celkom v súlade s vašou špecifikáciou. Ak by ste však dostali neúplnú objednávku alebo iný tovar ako ten, ktorý ste si objednali, alebo existuje nejaký iný dôvod, prečo nie ste s objednávkou spokojní, môžete objednávku alebo niektoré produkty z nej vrátiť a za tovar dostať plnú náhradu.

Pozrite si všetky pravidlá vrátenia

Zrušenie objednávky

Máte právo odstúpiť od nákupu do 14 dní od doručenia objednávky bez udania dôvodu. Na jednoduché uplatnenie svojho práva môžete použiť odkaz „Zrušiť moju objednávku“ v päte každej stránky alebo vo svojom účte Fruugo v časti „Objednávky“. Po uplatnení svojho práva na odstúpenie od objednávky vám zašleme e-mail s potvrdením. Ak vašu objednávku už predajca odoslal, poskytneme vám potrebné pokyny na vrátenie, aby sme zabezpečili rýchle spracovanie vrátenia peňazí.

Zobraziť úplné podmienky zrušenia objednávky