179,00 €
+ 6,99 € Doručenie

Control of Complex Systems
Predáva:

179,00 €

Na sklade
+ 6,99 € Doručenie

Politika vrátenia 14 dní

Ochrana kupujúceho

Spôsoby platby:

  • Značka: Unbranded

Podrobnosti o produkte

Podrobnosti o produkte

Control of Complex Systems

1. Introduction. - 1. 1 Complex Systems and Control. - 1. 2 Complex Engineering Systems. - 1. 3 The Role of Feedback. - 1. 4 Dynamics and Control. - 1. 5 The Nature of Failures. - 1. 6 Research Challenges. - 1. 7 About the Book. - 2. Modeling Complex Physical Systems. - 2. 1 Introduction. - 2. 2 The Modelica Project. - 2. 3 Composition Diagrams. - 2. 4 Modelica Details. - 2. 5 Non-causal Modeling. - 2. 6 Advanced Modeling Features. - 2. 7 Standard Libraries. - 2. 8 Future Development. - 2. 9 Conclusions. - 3. Passivity-based Control of Non-linear Systems. - 3. 1 Introduction. - 3. 2 Passivity and Stability Analysis of Feedback Interconnections. - 3. 3 Feedback Passivity and Stabilization. - 3. 4 Euler-Lagrange Systems. - 3. 5 Disturbance Attenuation and R oo Control. - 4. An Introduction to Forwarding. - 4. 1 Introduction. - 4. 2 C1 Dissipative Systems. - 4. 3 C1 Dis sipative Systems via Reduction or Extension. - 4. 4 Exact Change of Coordinates. - 4. 5 Approximate Change of Coordinates. - 5. Iterative Identification and Control Design. - 5. 1 Introduction. - 5. 2 Youla Parametrization. - 5. 3 A Generic Two-degree of Freedom Controller. - 5. 4 Optimization of the Generic Scheme. - 5. 5 A New Closed-loop System Parametrization. - 5. 6 Asymptotic Variances for K-B-Parametrization. - 5. 7 Iterative Controller Refinement. - 5. 8 Robustness and Sensitivity. - 5. 9 Product Inequalities. - 6. Learning Control of Complex Systems. - 6. 1 Introduction. - 6. 2 Model Structures for Learning. - 6. 3 Control Structures for Learning. - 6. 4 Learning Paradigms. - 6. 5 A General Framework for On-line Learning. - 6. 6 Validation. - 6. 7 Conclusions. - 7. Software for Complex Controllers. - 7. 1 Introduction. - 7. 2 An Evolving Paradigm. - 7. 3 Emerging Software Concepts. - 7. 4 On to Standardization. - 7. 5 Sample Complex Software Controllers. - 7. 6 The Future of Software for Control. -8. Fault-tolerant Control Systems. - 8. 1 Introduction. - 8. 2 Basic Definitions. - 8. 3 Analysis of Fault Propagation. - 8. 4 Analysis of Structure. - 8. 5 Recoverability. - 8. 6 Autonomous Fault-tolerant Control. - 8. 7 An Example: Ship Propulsio. - 8. 8 Summary. - 9. Fault Detection and Isolation. - 9. 1 The Principle of Model-based Fault Diagnosis. - 9. 2 Signal-based FDI Approach. - 9. 3 Quantitative Model-based FDI Approach. - 9. 4 Qualitative Model-based FDI Approach. - 9. 5 Summary. - 10. Residual Generation for FDI in Non-linear Systems. - 10. 1 Introduction. - 10. 2 Algebraic Approach. - 10. 3 Geometric Approach. - 10. 4 Conclusion. - 11. Predictive Methods for FTC. - 11. 1 Introduction. - 11. 2 Predictive Control. - 11. 3 Embedding Fault Tolerance in Predictive Control. - 11. 4 Model Adaptation and Management. - 11. 5 Modifying Control Objectives. - 11. 6 Current Industrial Practice. - 11. 7 Conclusions. - 12. Three-tank Control Reconfiguration. - 12. 1 The Benchmark Problem. - 12. 2 Reconfigurability Analysis. - 12. 3 Reconfiguration Based on a Qualitative Model. - 12. 4 A Hybrid Approach to Reconfigurable Control. - 12. 5 A Multi-model-based Reconfigurable Control. - 12. 6 A Neural Observer-based Approach. - 12. 7 Conclusions. - 13. Ship Propulsion Control and Reconfiguration. - 13. 1 Introduction. - 13. 2 Ship Propulsion System. - 13. 3 Structural Analysis. - 13. 4 Fault Detection: A Fuzzy Observer Approach. - 13. 5 Fault Detection: Non-linear Approach - 1. - 13. 6 Fault Detection: Non-linear Approach - 2. - 13. 7 Reconfiguration Using Software Redundancy. - 13. 8 Reconfiguration Using Predictive Control. - 13. 9 Summary and Conclusions. - 14. Learning Control of Thermal Systems. - 14. 1 Introduction. - 14. 2 On Thermal System Learning Control. - 14. 3 Controlling Kiln Heat Processing. - 14. 4 Controlling Reheat Furnace Processes. - 14. 5 Hierarchical Control for Quality Ceramic Tiles. - 14. 6 Learning Control ofFBC Combustion. - 14. 7 Conclusions and Future Research. - 15. Vibration Control of High-rise Buildings. - 15. 1 Introduction. - 15. 2 Energy and Information. - 15. 3 Analytical Mechanics and HRB Modelling. - 15. 4 Disturbance Decoupling. - 15. 5 Passivity Based Control. - 15. 6 Engineering Constraints and Feedback. - 15. 7 Feedback Control and Testing. - 15. 8 Conclusions and Future Research. - 16. Control of Helicopters. - 16. 1 Introduction. - 16. 2 Project History. - 16. 3 The COSY Program. - 16. 4 Hardware System. - 16. 5 Software. - 16. 6 Design of the Autopilot. - 16. 7 Future Development. - 16. 8 Conclusions. - 17. Satellite Attitude Control. - 17. 1 Introduction to the Attitude Control Problem. - 17. 2 Fault-tolerant Control of the 0RSTED Satellite. - 17. 3 Stabilization of the Angular Velocity of a Rigid Body. - 17. 4 Optimal Slew Maneuvers via Geometric Control Theory. - 17. 5 Attitude Control using Magnetorquers as Sole Actuators. - 17. 6 Predictive Attitude Control of Small Satellites. - 17. 7 Attitude Determination without Sensor Redundancy. - 17. 8 Summary. - Appendix A. List of Contributors. - Appendix B.
  • Značka: Unbranded
  • Kategória: Vzdelávanie
  • Počet strán: 482
  • Formátovať: Paperback
  • Jazyk: English
  • Umelec: Karl J. Aström
  • Dátum vydania: 2012/09/27
  • Vydavateľ / štítok: Springer
  • Fruugo ID: 337872348-741531648
  • ISBN: 9781447110743
Sľub

Záruka predávajúceho

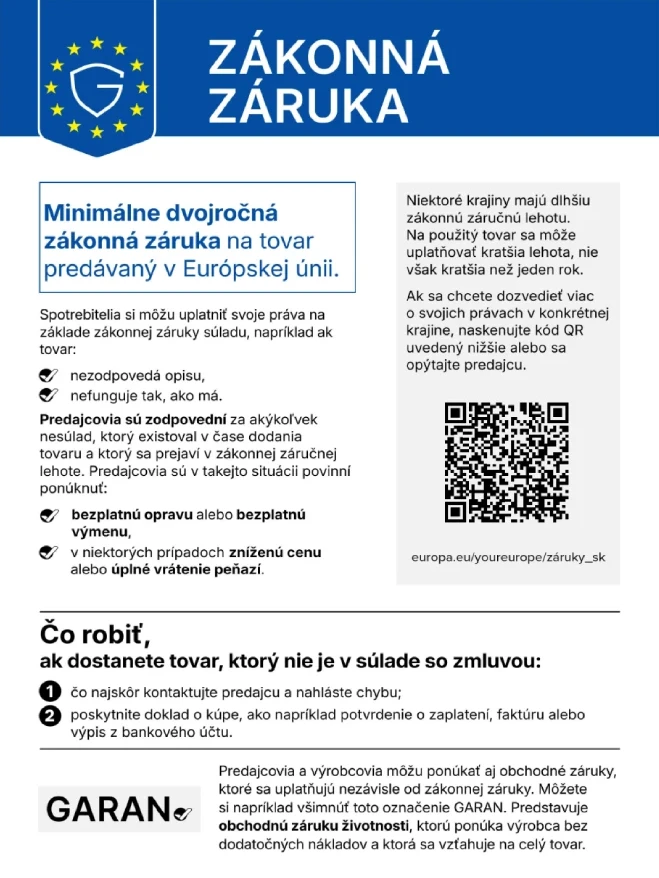
Vrátane 2-ročnej právnej záruky

Vaše spotrebiteľské práva v EÚ zahŕňajú bezplatnú minimálne 2-ročnú právnu záruku

Stiahnuť právnu záruku zhody
Doručenie

Doručenie

Odoslané do 5 dní

  • STANDARD: 6,99 € - Doručenie medzi st 14 októbra 2026–po 19 októbra 2026

Doručenie od Spojené kráľovstvo.

Vrátenie tovaru

Vrátenie a zrušenie objednávky

Vrátenie tovaru

Snažíme sa, aby sme výrobky, ktoré si objednáte, doručili celkom v súlade s vašou špecifikáciou. Ak by ste však dostali neúplnú objednávku alebo iný tovar ako ten, ktorý ste si objednali, alebo existuje nejaký iný dôvod, prečo nie ste s objednávkou spokojní, môžete objednávku alebo niektoré produkty z nej vrátiť a za tovar dostať plnú náhradu.

Pozrite si všetky pravidlá vrátenia

Zrušenie objednávky

Máte právo odstúpiť od nákupu do 14 dní od doručenia objednávky bez udania dôvodu. Na jednoduché uplatnenie svojho práva môžete použiť odkaz „Zrušiť moju objednávku“ v päte každej stránky alebo vo svojom účte Fruugo v časti „Objednávky“. Po uplatnení svojho práva na odstúpenie od objednávky vám zašleme e-mail s potvrdením. Ak vašu objednávku už predajca odoslal, poskytneme vám potrebné pokyny na vrátenie, aby sme zabezpečili rýchle spracovanie vrátenia peňazí.

Zobraziť úplné podmienky zrušenia objednávky